03 / Marine Engineering Club
Underwater ROV
I designed the frame, led vehicle integration, and implemented three-dimensional omnidirectional thrust vectoring in ROS.
- My role
- VP & Head of Design
- Period
- 2023–2024
- Scope
- Frame, waterproofing & control
- Evidence
- Workshop assembly & pool footage
Translate movement into thruster commands.
I implemented three-dimensional omnidirectional thrust vectoring in ROS. The software converts a requested vehicle movement into commands for the individual thrusters.
Working on the frame as well as the control software meant considering the thruster arrangement alongside the mechanical packaging.
- 01Requested movement
- 02ROS thrust vectoring
- 03Individual thruster commands
Get the complete vehicle into the pool.
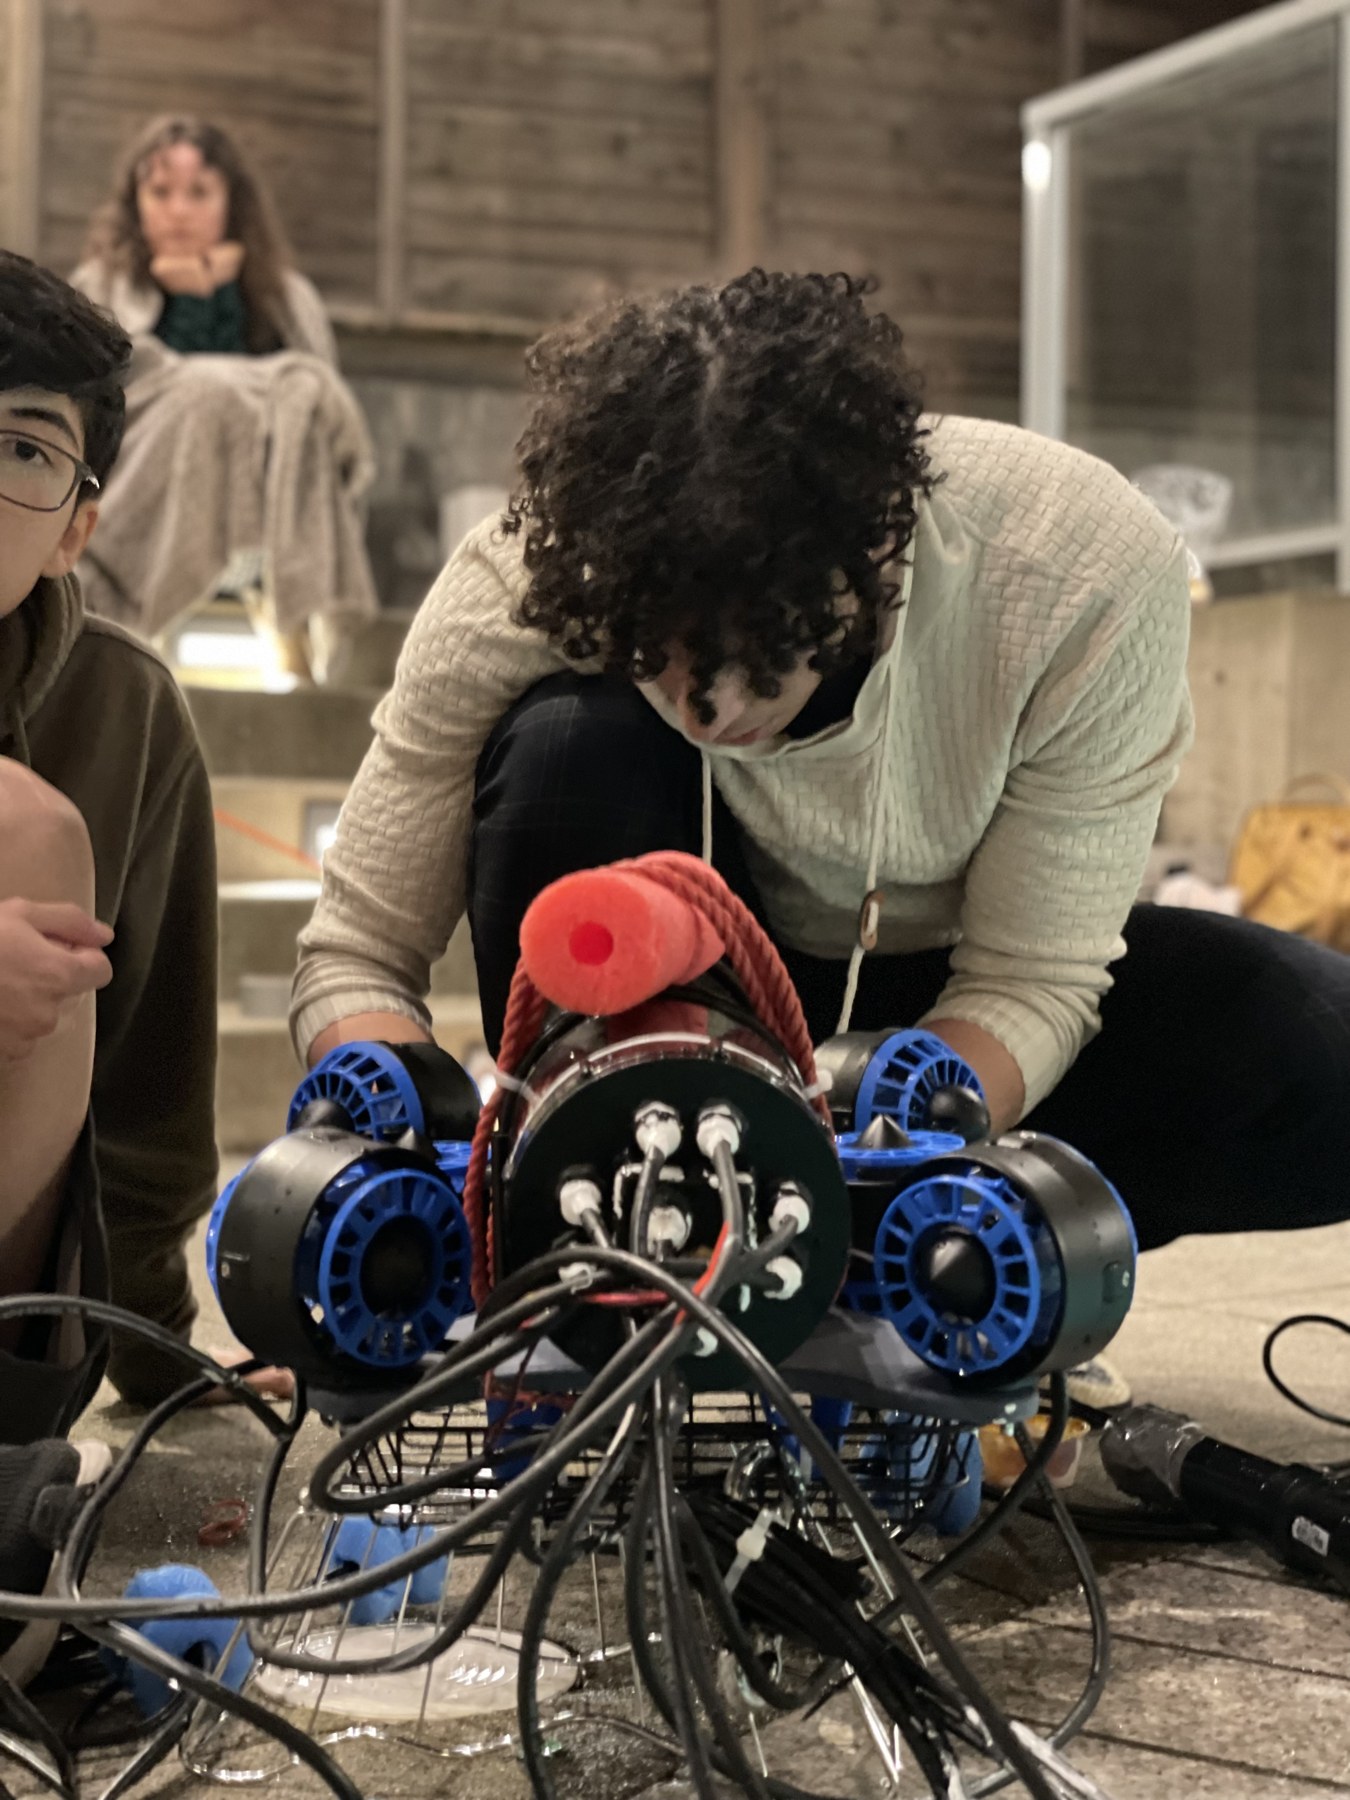
I led electronics mounting, waterproofing, and integration. The enclosure, mounts, thrusters, and cable routing had to fit together as one vehicle.
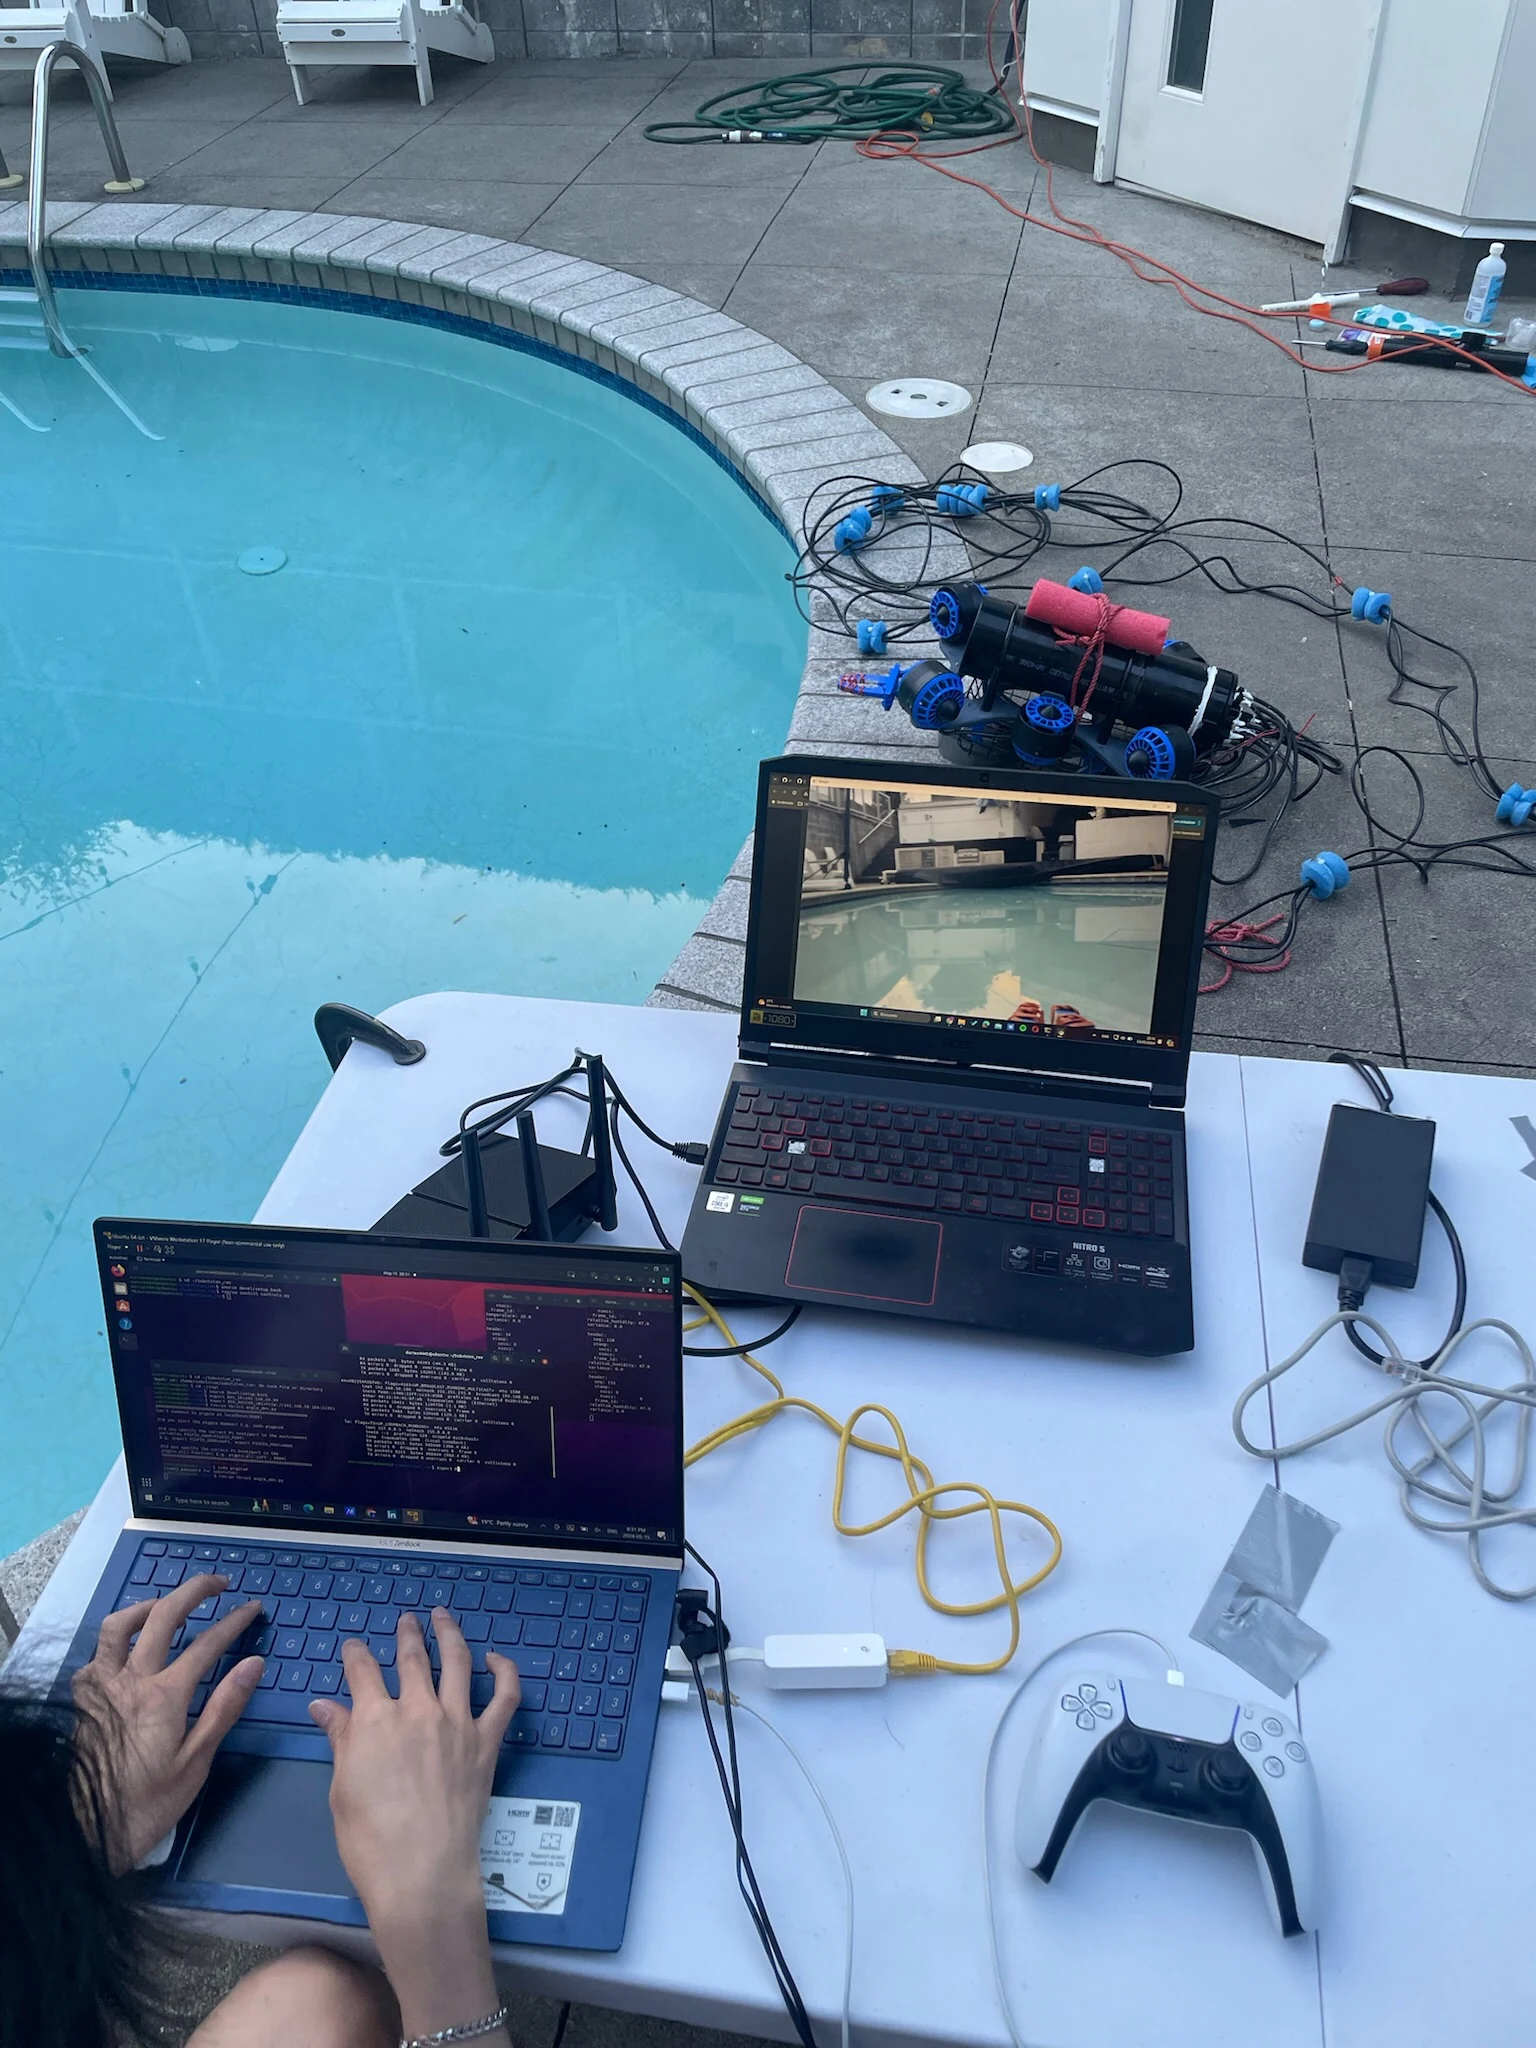
The workshop photo shows that assembly. The poolside setup brings together the tether, live video, laptops, and operator controls.
The footage demonstrates the integrated vehicle in a pool. It is not a quantified station-keeping or trajectory-tracking test.